INDEPENDENT RESEARCH. CONNECTED ACROSS EUROPE.
A spark.
A new world.
A shared space for curious minds.
Exploring AI, robotics and hardware,
one research question at a time.
Extraordinary things happen
when worlds connect.
Kratak Spoj means “short circuit.”
The spark when an unexpected connection opens a new possibility. Our story begins with collaborators across Europe, brought together by research questions at the meeting point of artificial intelligence, robotics and hardware.
We are building a shared space around that curiosity: somewhere to develop ideas, compare approaches and let promising questions grow into collaborative work. The initiative is taking shape through the research itself, one experiment and one connection at a time.
A shared direction, shaped by doing.
Our ambition is to grow into a distributed research lab and think tank. The foundations are practical: engineering experience, a willingness to investigate difficult problems, and an interest in intelligence that can act in the physical world.
This website is our growing public record. As the work develops, we will share papers, results, technical notes, dashboards and demos—making room for both the discoveries and the questions that lead to the next experiment.
+ 02 / NEW TERRITORIES
Six frontiers.
One restless curiosity.
From a single precise action
to intelligence working together.
Research directions we want to explore together.
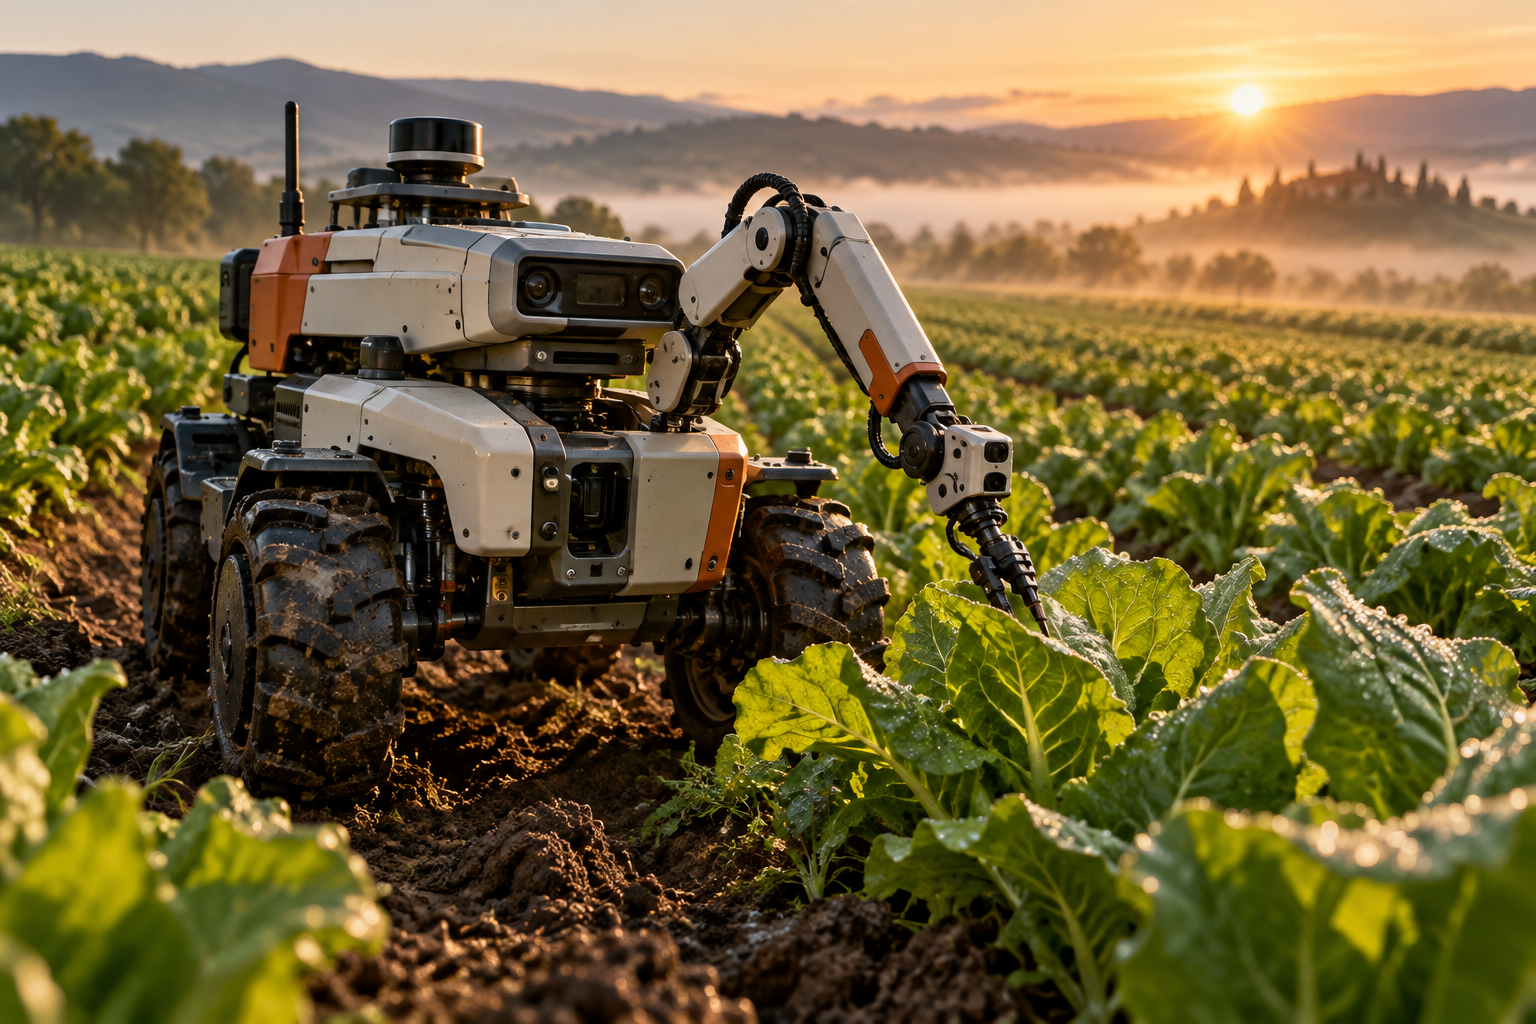 FIELD NOTES / 01AI-GENERATED RESEARCH VISION
AGRICULTURE & PRECISION SYSTEMS
A lighter footprint.
A smarter harvest.
Every plant tells a story. We want to help machines listen. Exploring field robotics that can understand crops, navigate changing terrain and put precision where it matters — at the leaf, not just the hectare.
Explore a collaboration+ INTELLIGENCE TAKES SHAPE
A mind. A body.
A world to shape.
To understand an object is one thing. To pick it up, feel its weight and place it with care is another. We’re exploring the connection between perception, dexterous manipulation and machines that learn through action.
Inside the researchA closer look at possibility.
Drag to explore · Arrow keys to rotate
+ 03 / UNDER THE SURFACE
Big questions.
Real-world stakes.
Research starts where the easy answers end. A look at the questions shaping our direction.
OUR RESEARCH AGENDA01Intelligence that understands spaceEMBODIED AI & WORLD MODELS
02Autonomy beyond the perfect demoROBUST NAVIGATION & CONTROL
03Hardware with a mind of its ownEDGE AI & ROBOTIC SYSTEMS
04Technology that earns our trustHUMAN–ROBOT INTERACTION
05From seeing to holdingDEXTEROUS OBJECT MANIPULATION
+ 04 / THE GROWING COLLECTION
From questions
to shared work.
Engineering foundations today.
Papers, experiments and new results
as the collection grows.
The collection begins with prior engineering experience that informs our direction. These projects predate Kratak Spoj. As new work is ready to share, it will join this record with its context, current stage and supporting material.
Loading the collection…
A collection in progress. New material will be added as it becomes ready to share.
+ 05 / THE NEXT CONNECTION
IDEAS WELCOME. CURIOSITY REQUIRED.Got a wild idea?
Let’s make sparks.
Good research often starts with a question shared between people who see the world differently.
Have an idea for an experiment or a shared research direction? Share the question, the context and what you would like to explore together.